Agile Flex 35D Capabilities, Applications & Regional Support
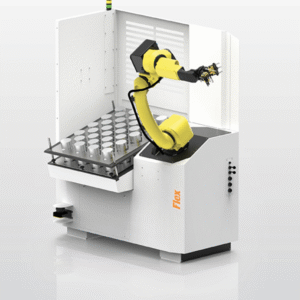
The Agile Flex 35D is an multi-layer drawer automation system for larger CNC-machined parts. It is configured to move raw and completed workpieces between organized storage and the CNC machine while machinists remain available for setup, process control, inspection, and other skilled work. A.W. Miller Technical Sales supplies and supports Agile robotic machine-loading systems throughout New York, Pennsylvania, Maryland, Delaware, Southern New Jersey, and Quebec, with application review, cell integration, installation, training, and regional service.
A FANUC M-20iD/35 robot provides a 35 kg payload with a standard double three-jaw gripper. Four drawers are standard and eight are optional. Published part capacity covers diameters from 1 to 6 inches; double-gripped workpiece weight is limited to 17.5 lbs, and each drawer is rated to 220 lbs. Final system capacity must be confirmed with the complete part, gripper, robot reach, storage arrangement, machine interface, safety layout, cycle-time target, and unattended production plan.
Applications
Applications commonly evaluated for the Agile Flex 35D include:
- billet-fed turning work
- multiple part numbers in one cell
- larger chucking components
- extended unattended production
Why Manufacturers Choose the Agile Flex 35D
Four- to Eight-Drawer Storage
The standard four-drawer arrangement supports parts as long as 6 inches; alternate two-drawer use accommodates lengths to 12 inches, while eight drawers increase quantity for shorter parts.
Multiple Part Families
Each drawer can carry its own nest plate, allowing the cell to queue different part numbers when gripper, machine, and program requirements are compatible. The production schedule must account for tooling and finished-part destinations.
Double Three-Jaw Gripper
A dual gripper reduces exchange time by carrying a raw and finished part through the machine-loading sequence. Jaw design and pressure settings must protect finished surfaces and maintain reliable pickup across stock variation.
Drawer Access During Production
The drawer format organizes raw and finished work while preserving a compact cell layout. Safe operator replenishment depends on the validated scanner zones, drawer interlocks, and robot state.